全国中文核心期刊
中国科技核心期刊
RCCSE核心期刊
SCD核心期刊
    • 2026 Volume 47 Issue 5
      Published: 10 September 2026


    • Select all
      |
    • LI Shengqin, GONG Shengxin
      Download PDF ( )   Knowledge map   Save
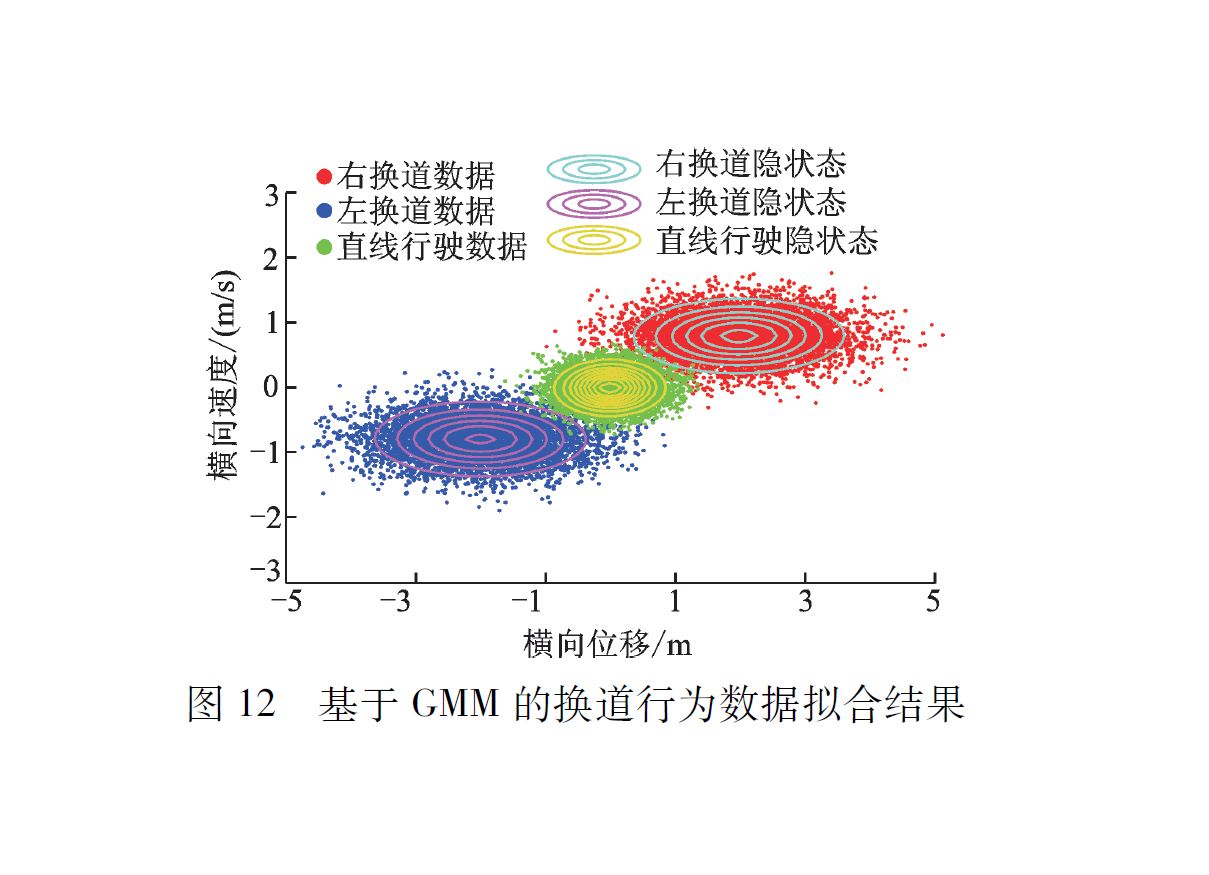
      To address the issues of poor generalization, susceptibility to catastrophic forgetting and degraded recognition performance due to imbalanced sample distribution in traditional vehicle lane-changing intention vecognition models under dynamic high-speed driving scenarios, the dynamic replay hidden Markov model (DRHMM) integrating experience replay strategy was proposed. Based on the NGSIM I-80 highway dataset, three types of valid trajectories including straight driving, left lane-changing and right lane-changing were extracted through trajectory splicing and reconstruction. Using Gaussian distribution parameter fitting, the lateral displacement and lateral velocity were selected as input features for the model. The experience replay strategy was introduced into the Gaussian mixture model-hidden Markov model (GMM-HMM) framework, and the experience replay buffer was constructed to store historical training samples. By mixing the new and old samples during training, the catastrophic model forgetting was suppressed, and the adaptability to dynamic driving environments was enhanced. The sliding time window of 3.00 s was set to conduct the comparative experiments among three models of HMM, GMM-HMM and DRHMM. The results show that by the DRHMM, the lane-changing intention recognition accuracy of 92.99% is achieved with recognition delay of only 0.69 s, which demonstrates significantly better overall performance than the comparison models.
    • HU Jie1, 2, WANG Pengfei1, 2, ZHANG Pei1, 2, LIU Yuting1, 2
      Download PDF ( )   Knowledge map   Save
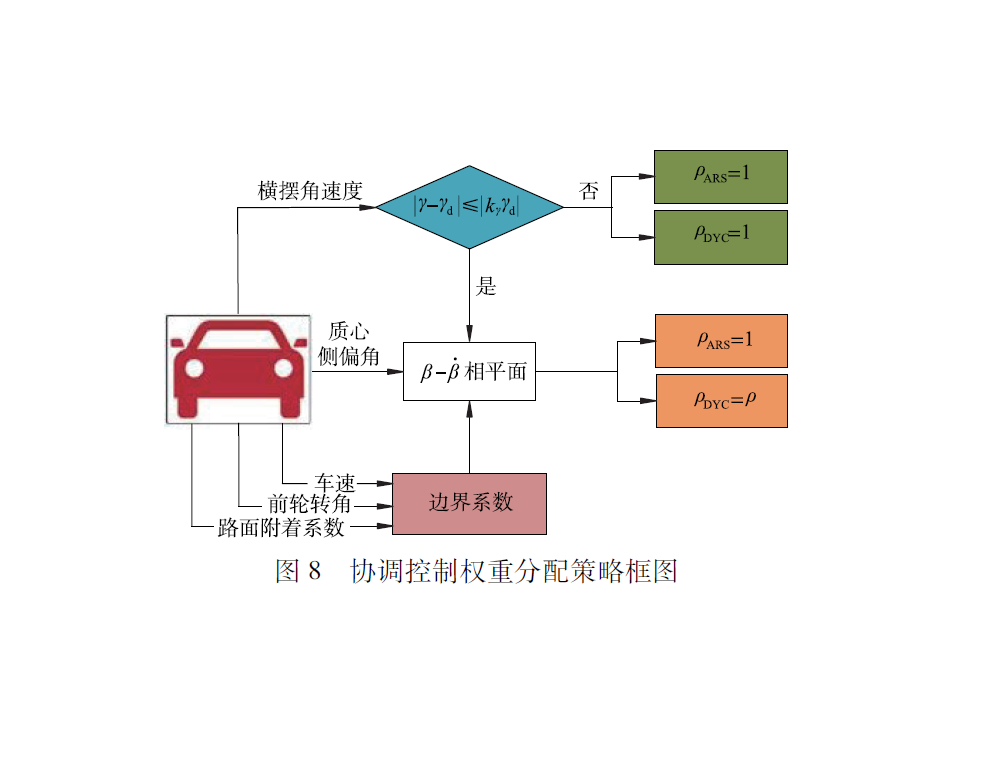
      To solve the instability issue of distributed drive vehicles running on high-speed and low-adhesion road surfaces, the joint coordinated control strategy for active rear steering and direct yaw moment control was developed. In the proposed scheme, the hierarchical control architecture was adopted. The phase plane method was used to define the vehicle stability region, and the yaw rate threshold method was applied to supplement the stability judgment criteria. By the upper-layer coordination controller, the control weights for the two subsystems were dynamically distributed according to the stability region, while in the lower-layer controller, the linear quadratic regulator was utilized to realize the rear wheel steering angle control. When the vehicle was detected to be on the verge of instability, the super-twisting sliding mode control was adopted to calculate the required additional yaw moment. With the tire load ratio as constraint, the quadratic programming algorithm was employed to achieve optimal four-wheel torque distribution and implement direct yaw moment control. The simulations were conducted under two typical operating conditions of medium-high speed on icy road surfaces and high speed on wet cement road surfaces. The experimental results verify that the proposed coordinated control strategy can remarkably improve the vehicle maneuverability and driving stability and effectively reduce the risk of vehicle instability.

    • HE Ren, XIE Yukun
      Download PDF ( )   Knowledge map   Save
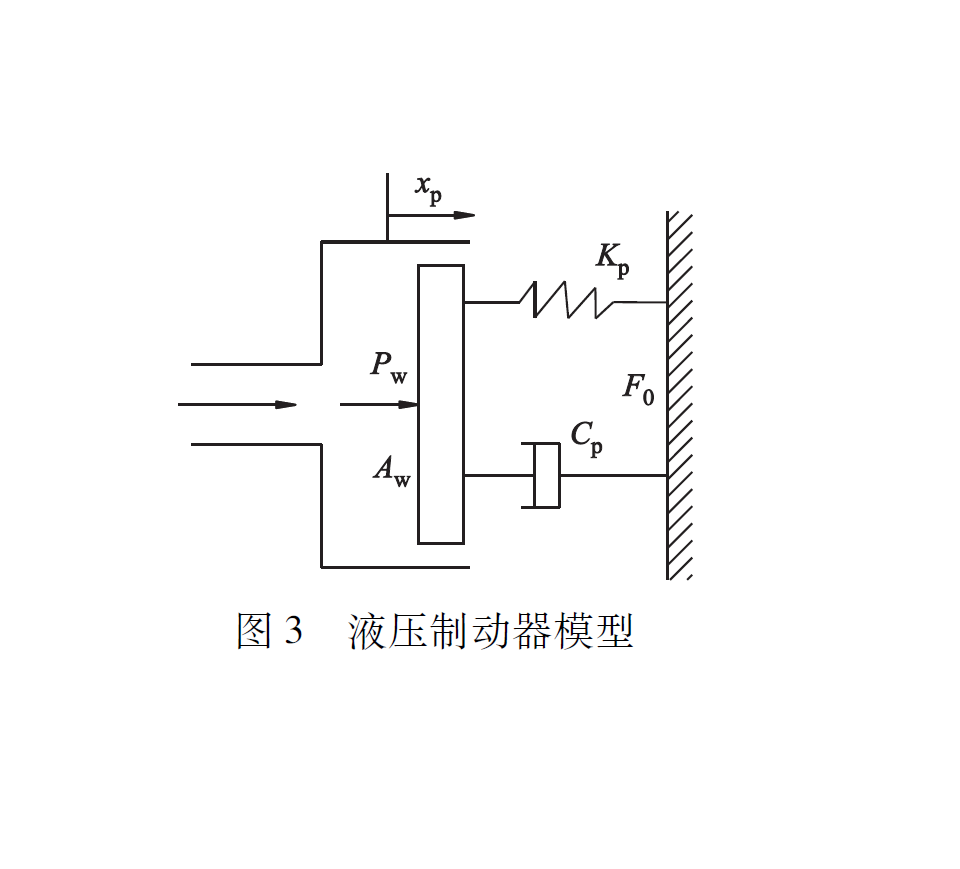
      To solve the problems of speed asynchrony and body instability among wheels during compound braking of distributed drive electric vehicles (DEVs)caused by external disturbances or changes in road conditions, the synchronous coordination control strategy for compound braking of DEVs was proposed. The synchronous coordination control strategy for compound braking was designed based on the control objectives of synchronization of yaw rate and wheel speeds, and the synchronous coordination among wheels was improved by applying the additional yaw torque and synchronous coordination torque while maintaining braking stability. Based on the non-singular fast terminal sliding mode control theory, the braking synchronous coordination controller for distributed drive electric vehicles was designed. The compound braking force distribution strategy was redesigned for the folio road surface.The simulation results show that the proposed control strategy can effectively improve the synchronization and coordination among wheels and the stability of the vehicle during compound braking, and it can reduce the risk of wheel locking.
    • LYU Yuejing1, WANG Xinyue1, ZHANG Mengmeng2, ZHANG Hong3, FENG Yuqin4, 5
      Download PDF ( )   Knowledge map   Save
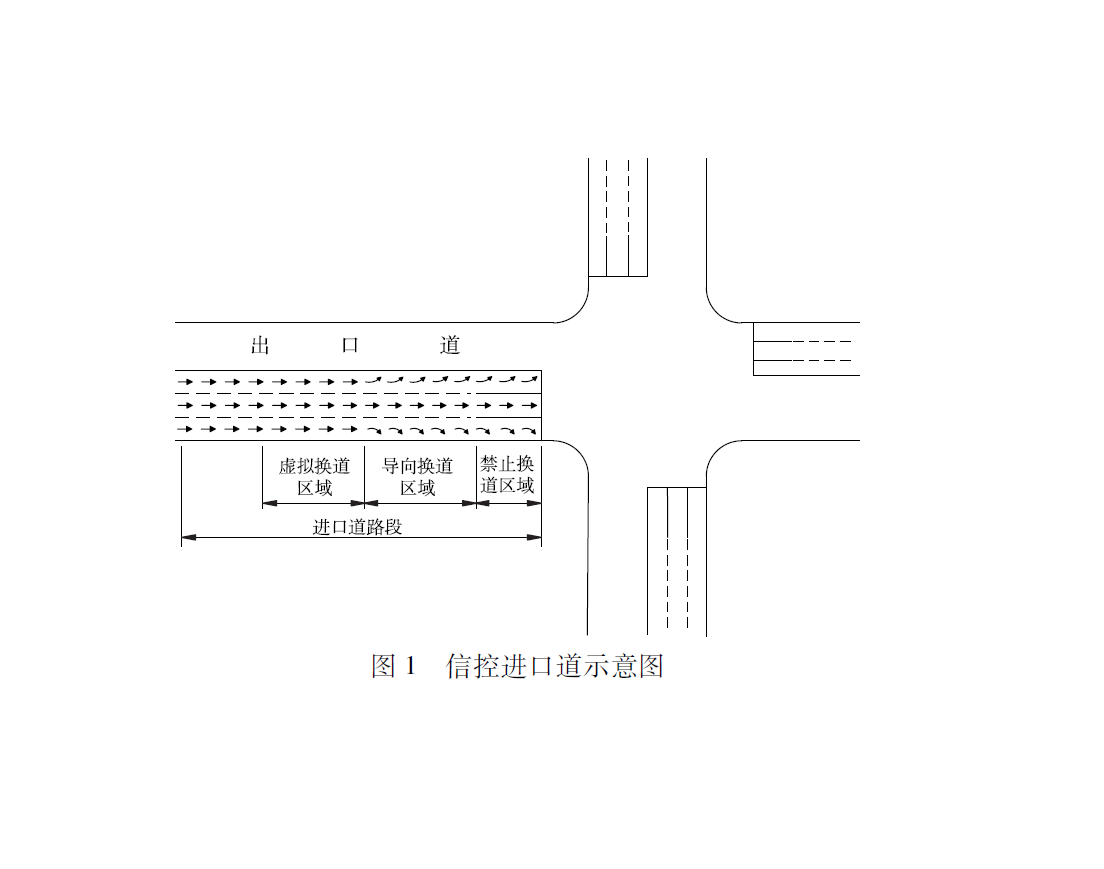
      To reduce the negative impact of vehicle lane-changing on the traffic flow operation of entrance lane, the lane-changing control strategy of heterogeneous traffic flow at the signalized control entrance lane was proposed. The traffic flow was analyzed,and the function area of entrance lane was divided to construct the virtual lane-changing area. The influence factors on vehicle lane-changing were analyzed, and the lane-changing control strategy of heterogeneous traffic flow based on virtual lane-changing zone was proposed. The traffic flow model of cellular automata was built,and the following rules were determined. Taking the traffic flow speed as evaluation index, the simulation analysis under different entering probability environment was carried out, and the lane-changing strategy was verified based on the virtual lane-changing area. The results show that the optimal length of virtual lane-changing zone is 150 m,and the key control point of the entering probability of the lane-changing strategy under the optimal length of virtual lane-changing zone is 0.5. Compared with the traditional lane-changing strategy, when the entering probability is greater than or equal to 0.5, the lane-changing strategy based on the virtual lane-changing zone can increase the running speed of traffic flow by 32.61%. On the contrary, the effect of traditional lane-changing strategy is better.
    • GULBAHAR Tohti1, GONG Yutao1, ORKIN Rahim2, MAMTIMIN Gheni1, LI Guanghao1, XUE Hairun1
      Download PDF ( )   Knowledge map   Save
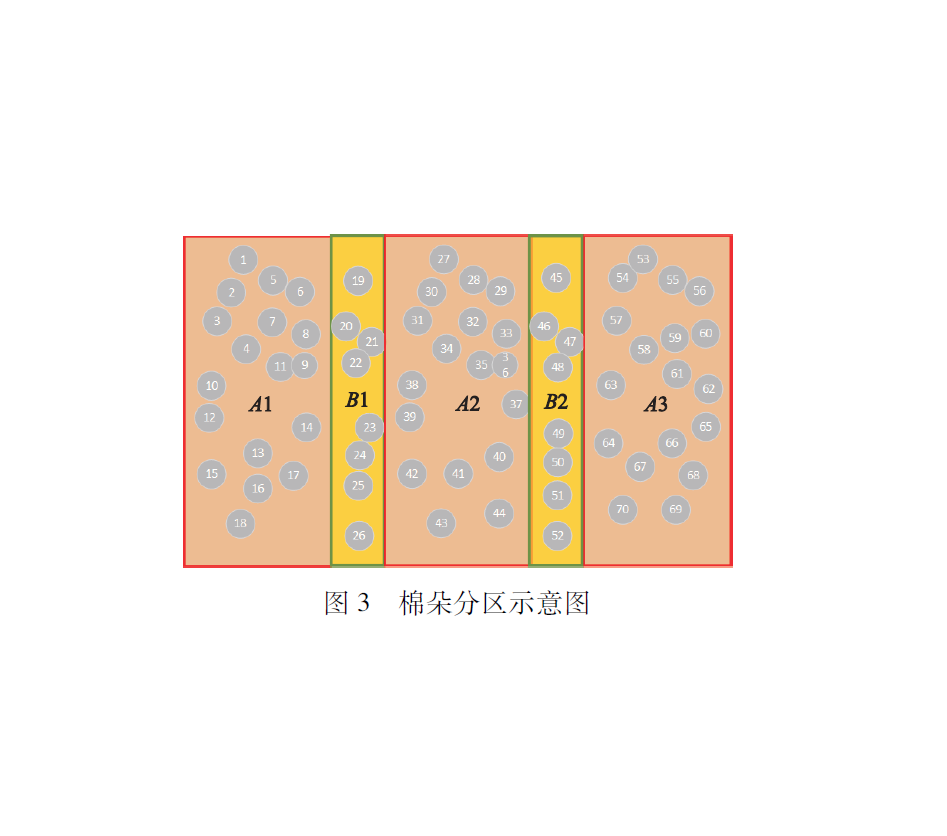
      To improve the cooperative operation efficiency of multi-arm picking robots in Xinjiang cotton fields, the task planning of multi-arm cooperative picking robots was analyzed,and the task planning problem was formulated as new traveling salesman problem. The optimization method based on the three-arm sparrow search algorithm was proposed. The experimental results show that for solving the problem of picking cotton bolls with the same distribution and quantity, the proposed task planning method reduces the operation traversal time by 84.18% compared to the single-arm sparrow search algorithm, and the traversal time of single robotic arm is approximate 6.32 times that of the proposed method. The task planning method based on the three-arm sparrow search algorithm can coordinate the operation tasks of the multi-arm picking robot system, avoid collisions between arms, traverse all cotton bolls in shorter time and improve operation efficiency.
    • QIAN Pengfei1, LIU Haiyang1, CAO Yuxuan1, HUANG Kai1, SHEN Haijun2
      Download PDF ( )   Knowledge map   Save
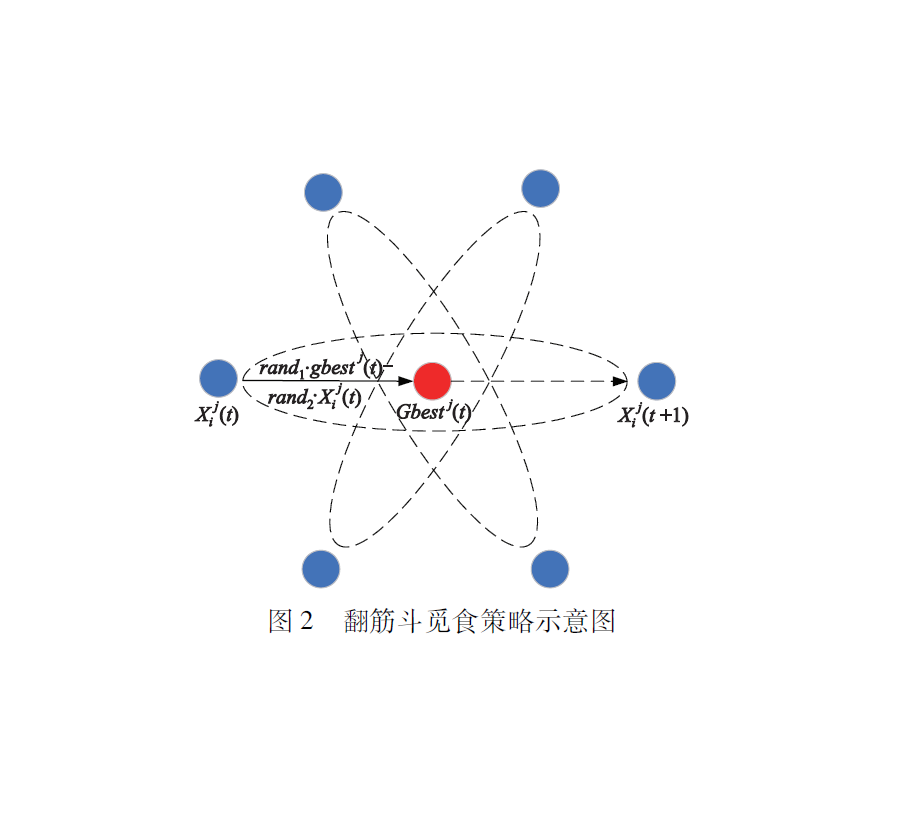
      To solve the problems of low efficiency and poor adaptability to complex operating conditions in traditional tuning of pressure controller parameters due to the relying heavily on manual trial-and-error based on empirical experience,the scheme for optimizing controller parameters based on the improved particle swarm optimization (PSO) algorithm was proposed. By the proposed algorithm, the global search capability and optimization performance were improved by removing the velocity term in the traditional position update formulation and incorporating chaotic mapping and somersault foraging strategies. The simulation comparison results on 10 benchmark functions show that the improved algorithm is more advantageous in terms of overall performance. The pressure control results for 30 L chamber show that compared to the trial-and-error method, the optimization method achieves 56.8% reduction in the steady-state error of system under the leakage condition. When the optimized parameters are further applied to the step pressure control under closed condition and constant leakage condition, the system steady-state errors are less than 40 Pa and 90 Pa, respectively, which illuminates that the optimization scheme has good adaptability under different conditions.
    • BAO Xu1, 2, YANG Zhiqiang1, 2, ZHANG Wence1, 2
      Download PDF ( )   Knowledge map   Save
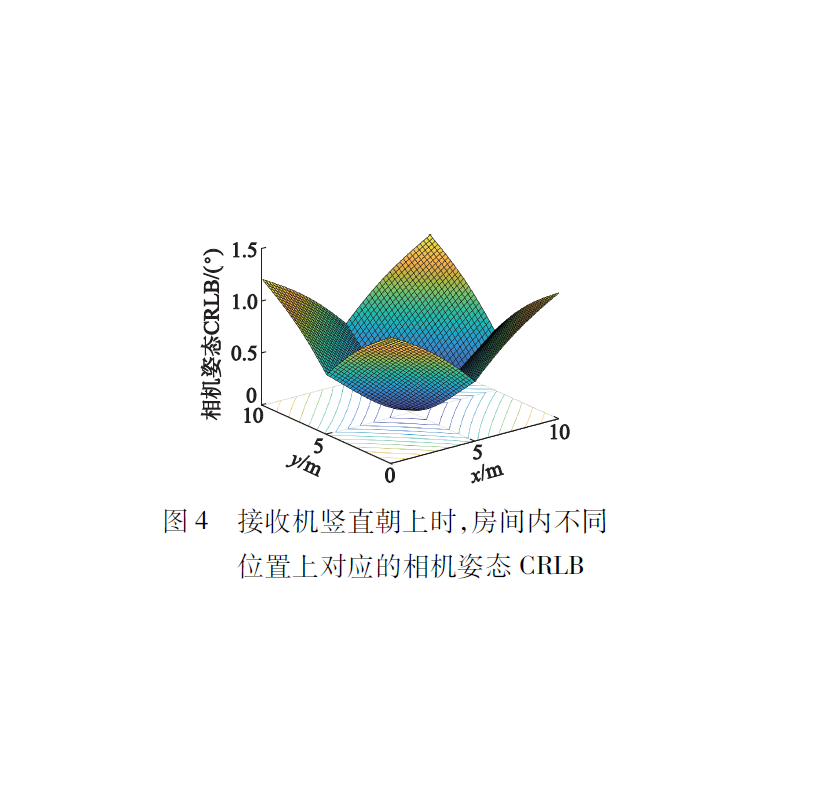
      To optimize the parameters of indoor visible light positioning (VLP) system based on image sensors (ISs), the in-depth analysis of the theoretical performance bound of the system was conducted. The multiple light-emitting diodes (LEDs) were employed as transmitters with a camera as receiver. Without prior knowledge of the camera position and orientation, the accurate camera localization was achieved by analyzing the geometric relationship between the positions of LEDs in the world coordinate system and their pixel coordinates on the camera image plane. In the typical indoor environment, the effect of white Gaussian noise on the imaging process was considered, and the Cramér-Rao lower bound (CRLB) for the three-dimensional coordinates and orientation of the camera was derived. The theoretical analysis was verified through the comparison between simulation and experimental data. The results show that the indoor VLP system based on commonly used LEDs and ISs can theoretically achieve the millimeter-level positioning accuracy, and the performance is mainly affected by the distance between the camera and LEDs, the camera focal length, the camera orientation and the number of LEDs.
    • SHEN Yue, PANG Dongling, LIU Hui
      Download PDF ( )   Knowledge map   Save
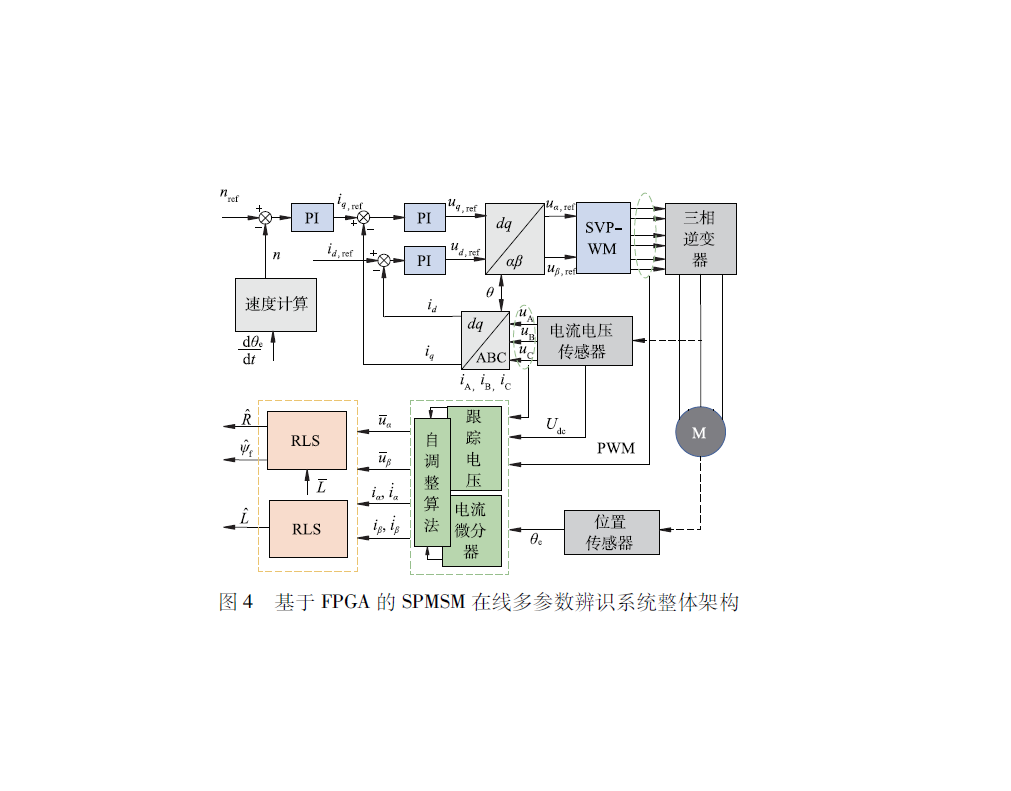
      The adaptive sampling point algorithm based on field programmable gate array (FPGA) was proposed to solve the non-ideal interferences in the multi-parameter identification of surface-mounted permanent magnet synchronous motor (SPMSM) using switching frequency harmonics. The switching frequency harmonics filtered out in the motor control system were introduced into the SPMSM model. The inductance was calculated independently, and the stator resistance and rotor flux linkage were identified step by step. The identification method was not affected by initial parameter values. The signal optimization was implemented on FPGA, and the high-frequency clock signals were used for voltage tracking, while the linear tracking differentiators were adopted to suppress the digital differential noise and reduce the errors caused by inverter nonlinearity. The sampling point self-adjustment rules were designed according to the states of switching modulation signals to improve the adaptability of the algorithm. The experimental results show that the average identification error is less than 1.0% at medium and high speeds, and the maximum error is within 4.5% at low speeds. When the identified parameters are applied to decoupling control under parameter mismatch, the current fluctuation is reduced, and the speed regulation time is shortened, which illuminates that the overall control performance of the system is greatly improved.
    • NIU Penghao, YANG Lin, LI Zijian, ZHAO Yuzhuang
      Download PDF ( )   Knowledge map   Save
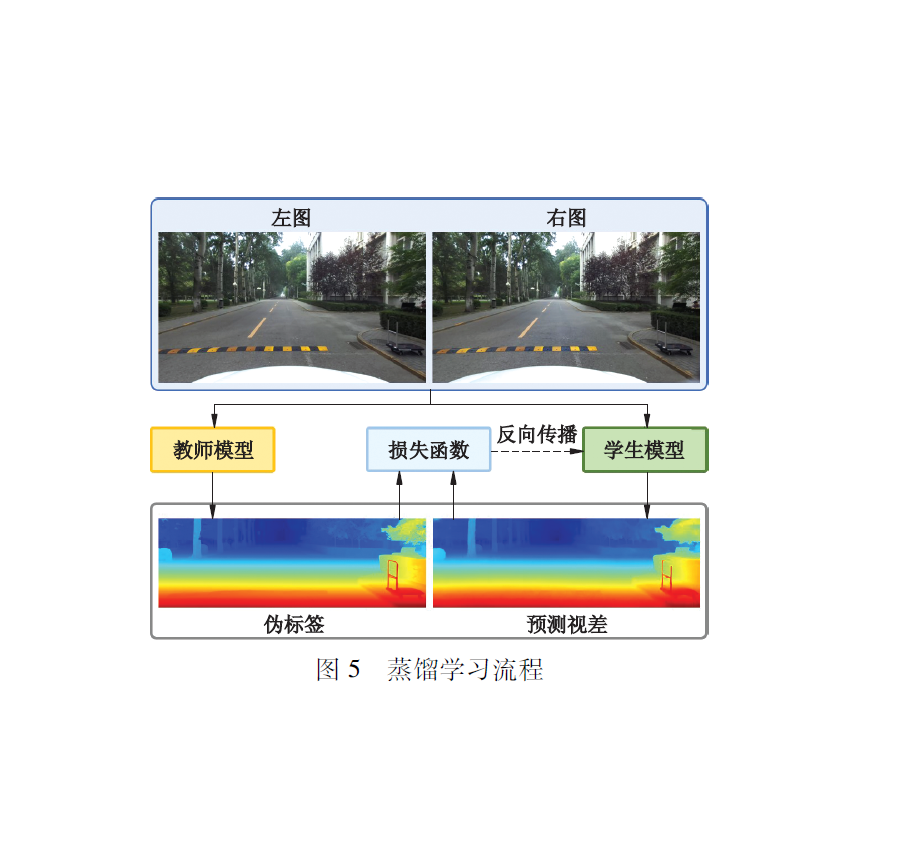
      To solve the problems of the stereo matching networks application to road preview systems with insufficient training data, performance degradation of real-time network and poor stability for disparity prediction, the performance enhancement strategy of stereo matching network for road preview was investigated. The large-scale synthetic dataset tailored for stereo matching was rendered using Unreal Engine 5, and the effectiveness in boosting network performance was verified. Leveraging the theory of distillation learning, the high-performance stereo matching network was employed to generate pseudo ground-truth disparities for manually collected real-world data, and the disparities were used to train the real-time stereo matching network. During the training stage, the disparity consistency loss supervision term was introduced into the loss function to enhance the stability of disparity prediction. The test results on the RSRD dataset show that the DLNR network finetuned with the road preview synthetic dataset achieves 84.5% reduction in the end-point error (EPE) metric. On the locally collected road-preview dataset, the Fast-ACVNet network trained via distillation learning exhibits 65.6% decrease in EPE, while the introduction of the disparity consistency loss leads to 55.9% improvement in disparity prediction stability. In speed-bump distance measurement trials, the Fast-ACVNet network trained by the proposed comprehensive strategies shows the ranging error within 30 cm, indicating outstanding accuracy and stability with favorable road preview performance.
    • LIU Chao1, LIU Kang1, SHI Yulong2
      Download PDF ( )   Knowledge map   Save
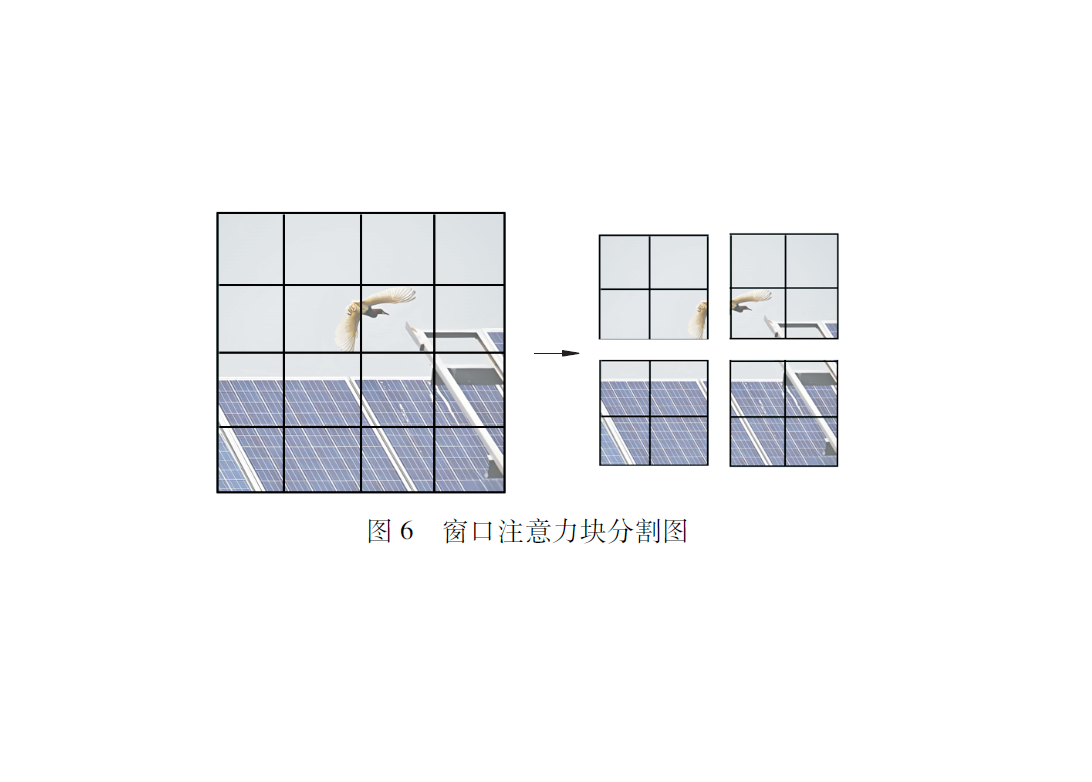
      The photovoltaic power stations in field environments are often disturbed by foreign objects of snow, weeds, bird intrusions and bird nests. The traditional detection algorithms suffer from background interference, low accuracy for small targets and low image resolution, which can not operate stably on embedded devices. Based on YOLOv7-tiny, the lightweight detection model was constructed. The Haar wavelet downsampling module was adopted to reduce the background interference, and the mixed attention module was added to enhance the detection performance of small targets, while the pixels-wise intersection over union loss function was used to solve the detection deviation caused by tilted photovoltaic panels. The experimental results show that by the optimized model, the precision of 95.8% is achieved with the recall of 95.4%, the mean average precision of 95.3% and nearly no change in model size and inference speed. After model conversion and TensorRT acceleration, the model is deployed on the Jetson TX2 platform to realize the real-time detection.
    • YUAN Xinhua1, HU Zhenguo1, CHEN Zeyu2, MENG Fuliang3, JIA Yufei1, ZHENG Shaoqiu1, ZHOU Kewu1, FEI Hongwei2, HE Kun4
      Download PDF ( )   Knowledge map   Save
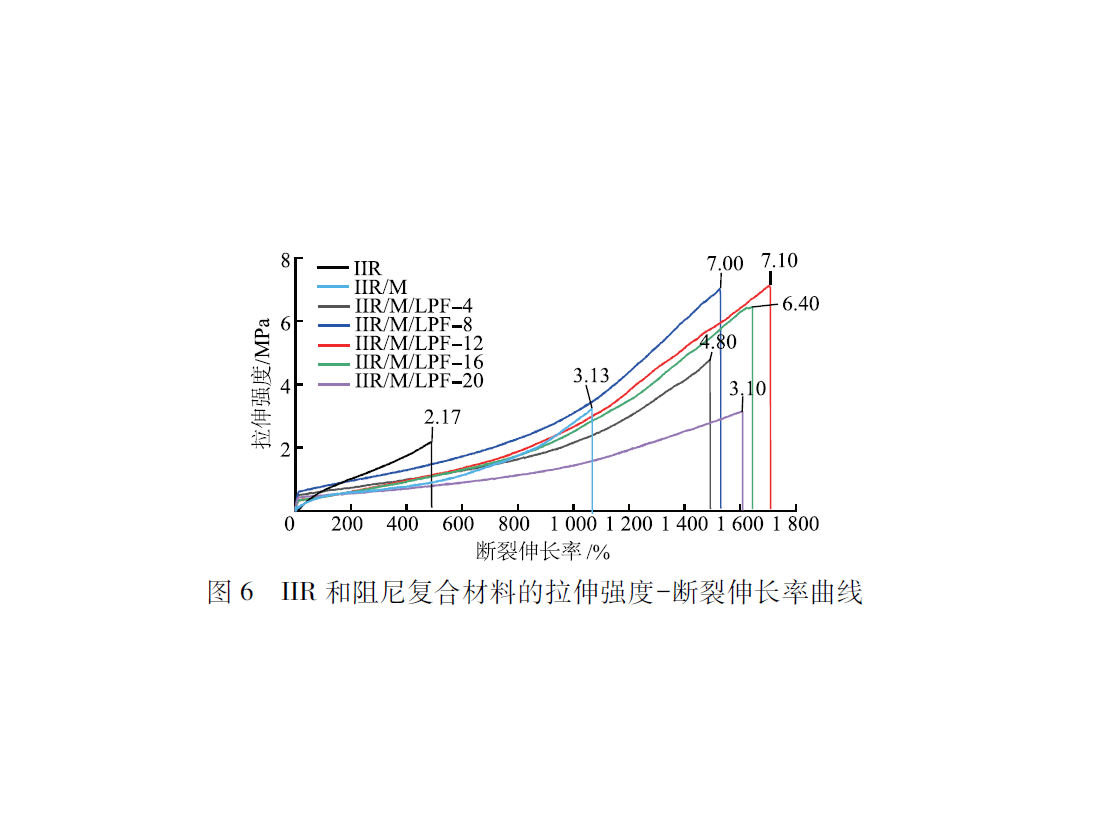
      To address the shortcomings of butyl rubber (IIR) with low damping factor and unstable damping performance at temperatures above room temperature, the lignin-based phenolic formaldehyde resin (LPF) was incorporated into the IIR matrix to prepare LPF/butyl rubber damping composite materials. The three-dimensional network structure formed between LPF and IIR was utilized to broaden the damping temperature range of the material and enhance the damping coefficient. The experimental results show that LPF exhibits favorable compatibility with IIR at the LPF content of 12 phr, whereas excessive LPF addition tends to trigger particle agglomeration and degrade composite properties. LPF contributes to improved mechanical properties of the damping composites. At 12 phr LPF content, the maximum torque reaches 6.8 dN·m with the elongation at break of 1 706%, and the tensile strength attains 7.1 MPa. Benefiting from the constructed three-dimensional network between LPF and IIR, the damping capacity of composites is remarkably enhanced with the damping factor remaining as high as 0.32 at 70 ℃. The thermal stability of LPF/IIR composites is significantly improved, delivering the char residue of 26.4% at 800 ℃, which is substantially superior to the 3.3% of pure IIR.
    • ZHANG Xiliang1, 2, WANG Junzhuo2, CHEN Cheng2, 3, GU Haiqin1, ZHANG Jiaqi2, XU Yunfeng2
      Download PDF ( )   Knowledge map   Save
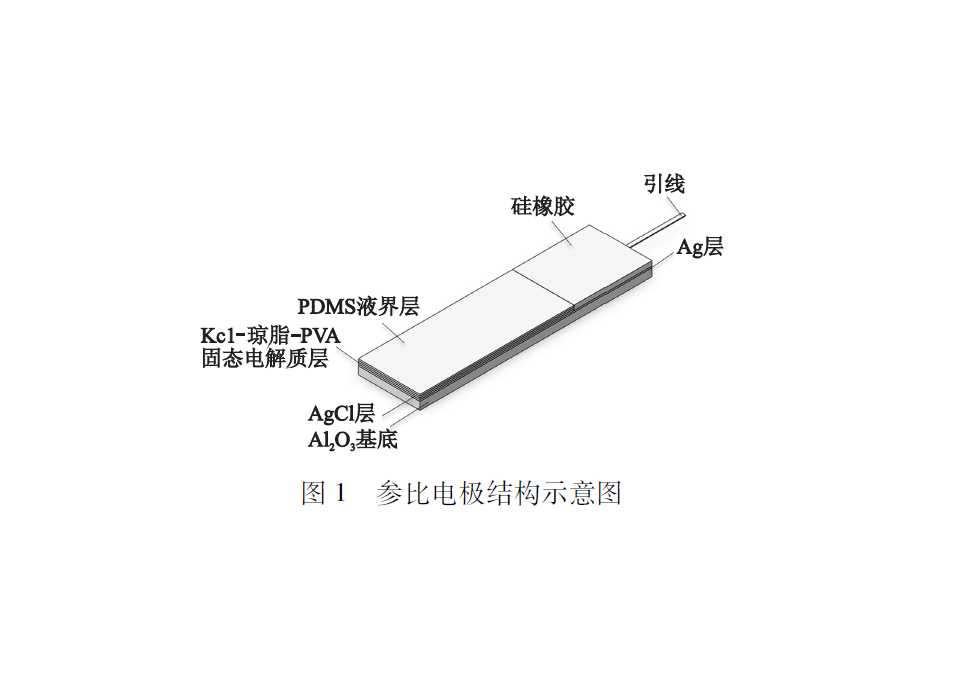
      To solve the poor adaptability of glass structure Ag/AgCl reference electrode to the online detection of cultivation substrate pH, the flat-type all-solid-state Ag/AgCl reference electrode was developed with KCl agar-polyvinyl alcohol (PVA) gel as electrolyte layer and cured polydimethylsiloxane (PDMS) as liquid junction layer for composite modification. The experiments were conducted to investigate the effect of the KCl solution concentration in the prepared electrolyte layer on the performance of reference electrodes. The results show that according to the physical characterization of the modified reference electrode surface by EDS and SEM, the KCl cubic crystals on the surface of the electrolyte layer are more uniformly distributed and densely packed as the concentration of the prepared KCl solution is increased. Among the reference electrodes whose electrolyte layers are prepared with KCl solutions at four concentrations (1.0, 2.0, 3.0 and 3.5 mol/L), the electrode fabricated using 3.0 mol/L KCl solution exhibits the lowest sensitivity to chloride ion concentration in saline solutions, and the electrode delivers the most stable output potential and outstanding reversibility in buffer solutions with different pH values. Fifty cycles of cyclic voltammetry tests in impedance solution reveal that the electrode possesses stable potential peak signals and minor potential drift. The pH sensor with commercial antimony working electrode demonstrates good sensitivity and accuracy in pH calibration and online detection of cultivation substrate. The developed PVA-PDMS composite-modified flat-plate all-solid-state Ag/AgCl reference electrode delivers stable reference potential and possesses moderate surface hydrophilicity, showing excellent adaptability for online pH detection of cultivation substrates.

    • CHEN Meng1, ZHANG Zhongqiu2
      Download PDF ( )   Knowledge map   Save
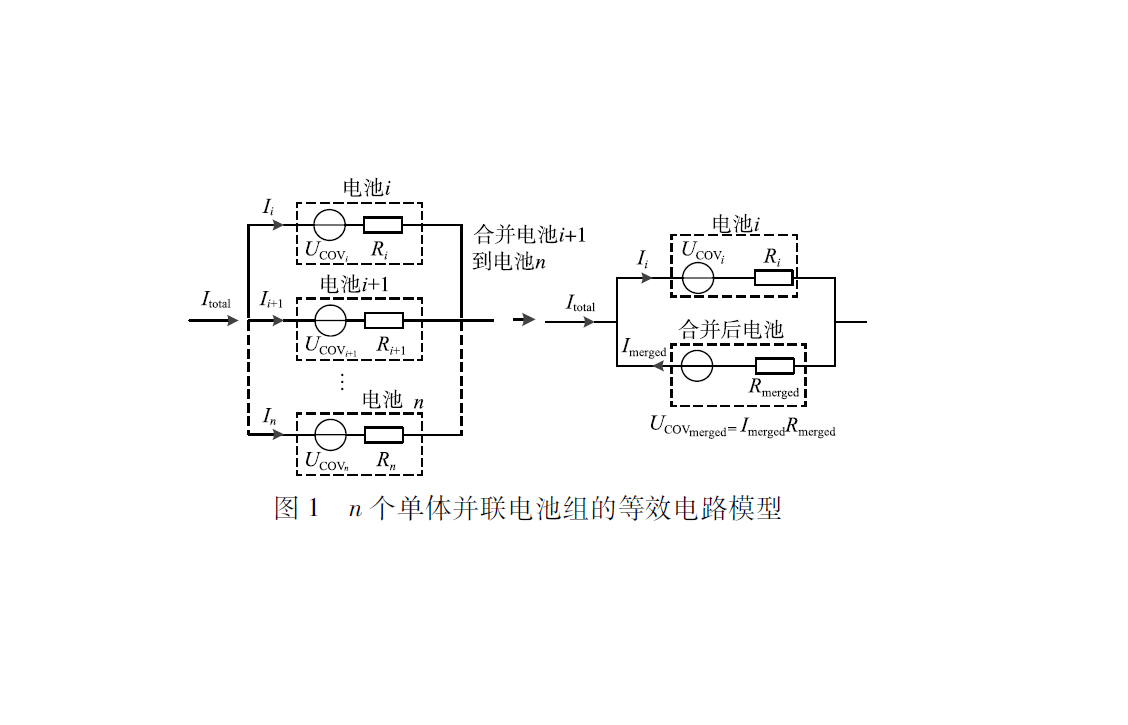
      The current research on battery pack consistency detection mainly focuses on series-connected battery packs, while the detection methods for parallel-connected battery packs are insufficient with single detection parameters and limited information characterization capability. To solve the problems, the consistency detection method for parallel-connected battery packs based on current ratio was proposed by constructing the equivalent circuit model of parallel batteries. Taking the product ratio of single battery capacity to internal resistance as core discrimination index, the consistency of battery packs was comprehensively characterized by integrating two key parameters of internal resistance and capacity. The multi-scenario comparative experiments were carried out from four dimensions of battery material, parallel quantity, charge-discharge rate and ambient temperature to verify the effectiveness and universality of the proposed method. The experimental results show that the maximum deviation of the current ratio-based consistency indicator tested via the method is 0.805, and the minimum deviation is 0.117 with stable and reliable detection accuracy. It can effectively meet the consistency detection requirements of parallel-connected battery packs under different working conditions.
    • WANG Shuang, YANG Zijiang, JING Shiyao, SHEN Chengjun, CHEN Hao
      Download PDF ( )   Knowledge map   Save
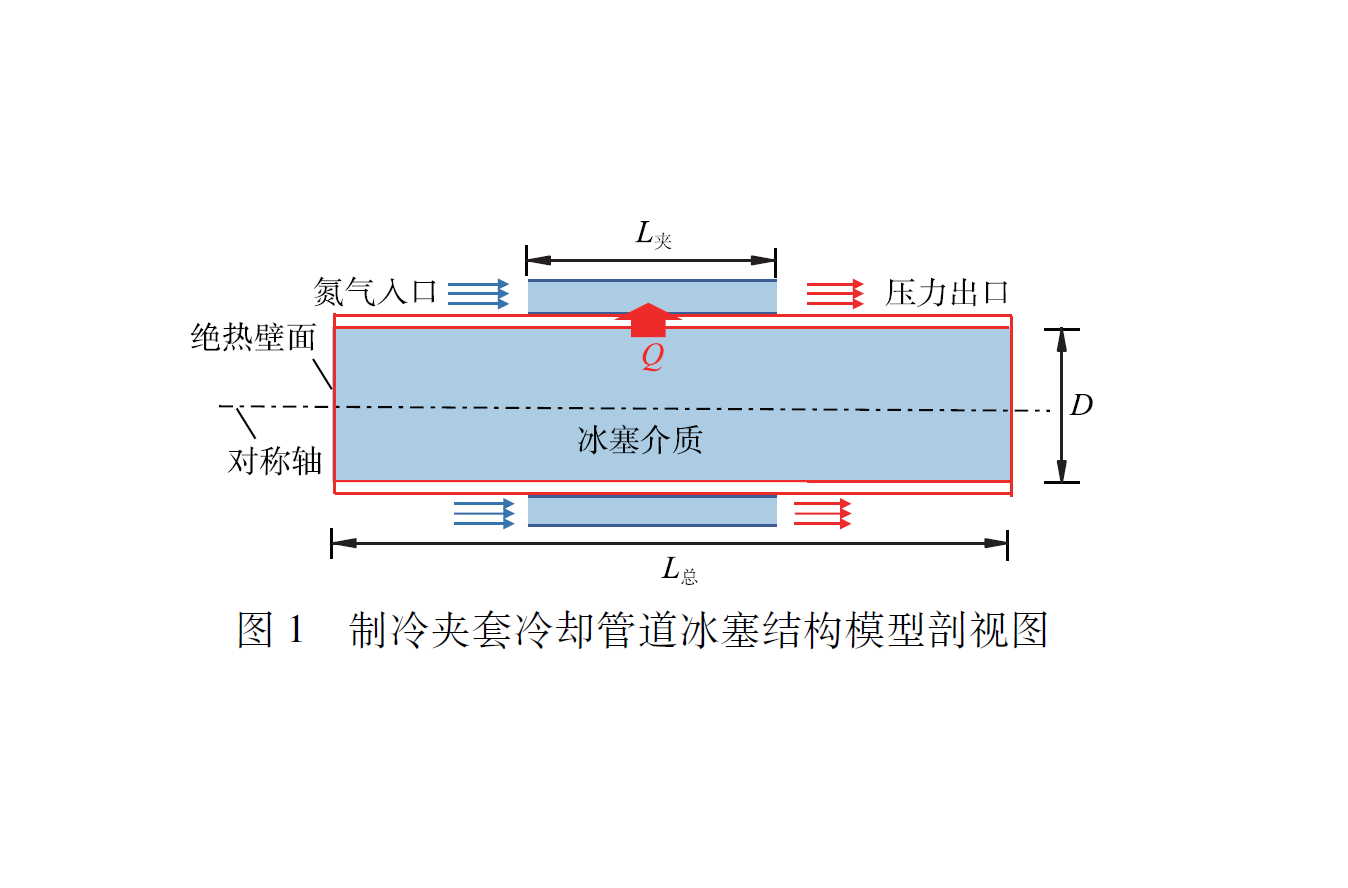
      To achieve the efficient transfer of low-temperature nitrogen cold energy, the influence law of the inlet velocity of nitrogen (0.1-1.2 m/s) in the jacket matching the 150 mm ice plug pipeline on the pipeline ice plug formation rate and the ice formation per unit mass of low-temperature nitrogen was investigated. On this basis, the influence law of swirling tapes with different twist ratios (0.2-0.7) in the nitrogen annular flow channel on low-temperature nitrogen heat transfer flux, ice plug formation rate and ice formation per unit mass of low-temperature nitrogen was further investigated. The results show that in the annular flow channel, increasing the nitrogen velocity can effectively improve the ice plug formation rate and the ice formation per unit mass of low-temperature nitrogen. The built-in swirling tape with twist ratio of 0.2 can increase the nitrogen heat transfer flux to 217 W (1.62 times higher than that without the swirling tape), and it can also increase the low-temperature nitrogen cold energy utilization rate to 28.55 cm3/kg (2.8 times higher than that without the swirling tape).
    • ZHAO Wei, WANG Haiwen, ZHANG Dingwen, ZHAO Wang
      Download PDF ( )   Knowledge map   Save
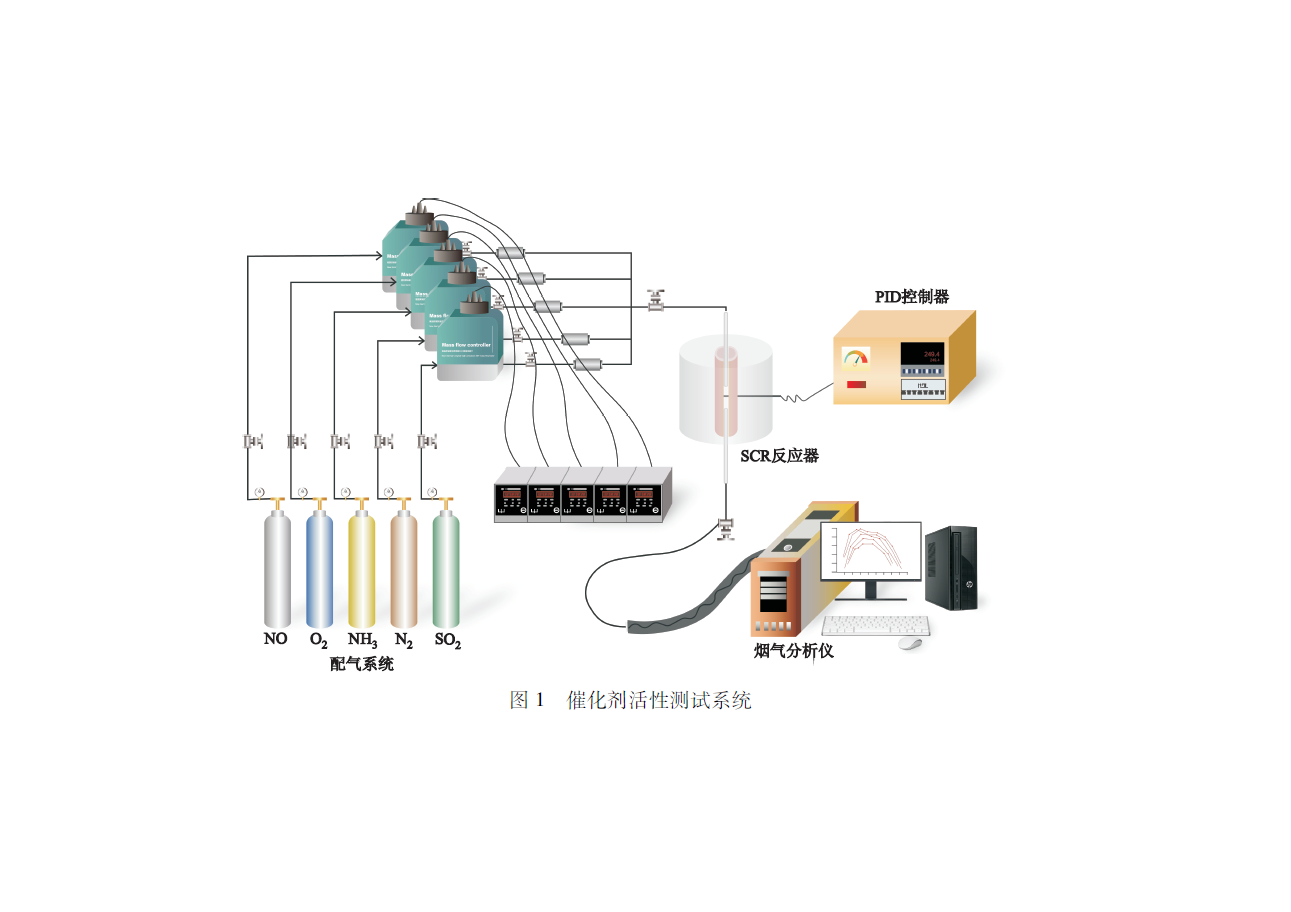
      The vanadium-titanium-based catalysts are mainly applied for the denitrification of medium-temperature and high-temperature flue gas, while they suffer from the biological toxicity of active vanadium components, narrow active temperature windows and poor low-temperature denitrification performance. To develop the environmentally friendly and non-toxic vanadium-free denitrification catalysts suitable for low-temperature working conditions, the BaTiO3 catalyst was prepared via the sol-gel method and modified by transition metal Mn doping. The microstructures and surface properties of the original and modified catalysts were systematically characterized by XRD, XPS, BET, NH3-TPD and EPR. The results show that Mn doping can effectively increase the content of surface chemisorbed oxygen and the number of surface acidic sites for optimizing the physicochemical properties of the catalyst. Activity tests verify that the Mn-modified BaTiO3 catalyst exhibits excellent low-temperature denitrification performance and wide active temperature window, and the NOx conversion rate can be maintained over 80.0% within 100-230 ℃ with the maximum conversion rate of 99.3%.